> GCS BOOT SEQ v7.1 .......... OK > TELEMETRY LINK @ 10 Hz ..... OK > OPERATOR IDENTIFIED:
TYLER CALVET
SCROLL TO ACQUIRE SIGNAL ▼
// About the operator
I build the software that keeps uncrewed vehicles on mission — ground control stations, satellite comm links, and real-time telemetry pipelines for machines in the air, on the water, and in the field.
Day to day that means Python backends (FastAPI, Flask) speaking MAVLink to autopilots, Android apps driving Iridium modems over USB serial, and Raspberry Pis doing serious work in places with no cell coverage. If it moves without a person on board, I've probably written a console for it.
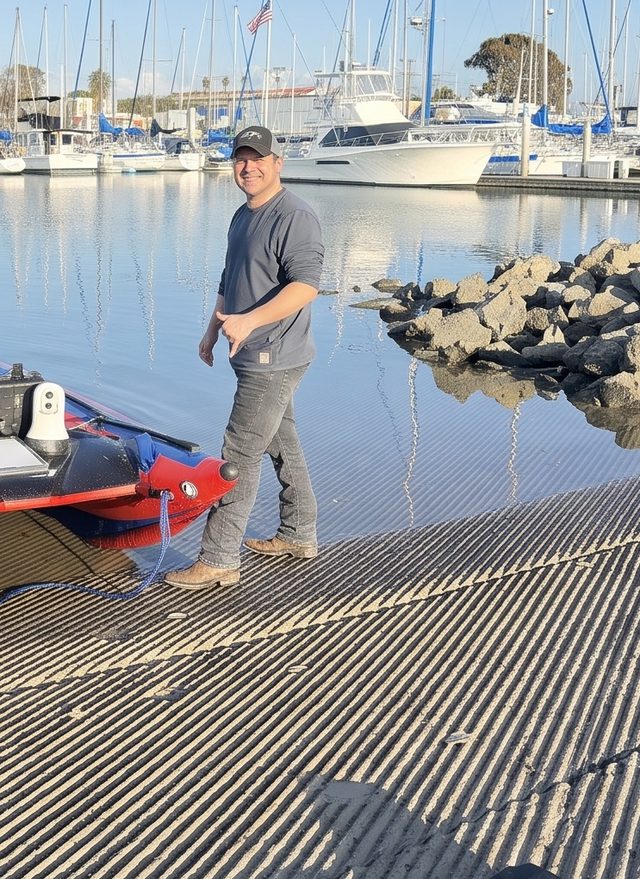
Status: in the field
Last fix: marina launch ramp
// Mission log
Select an entry to open the case file
Overview
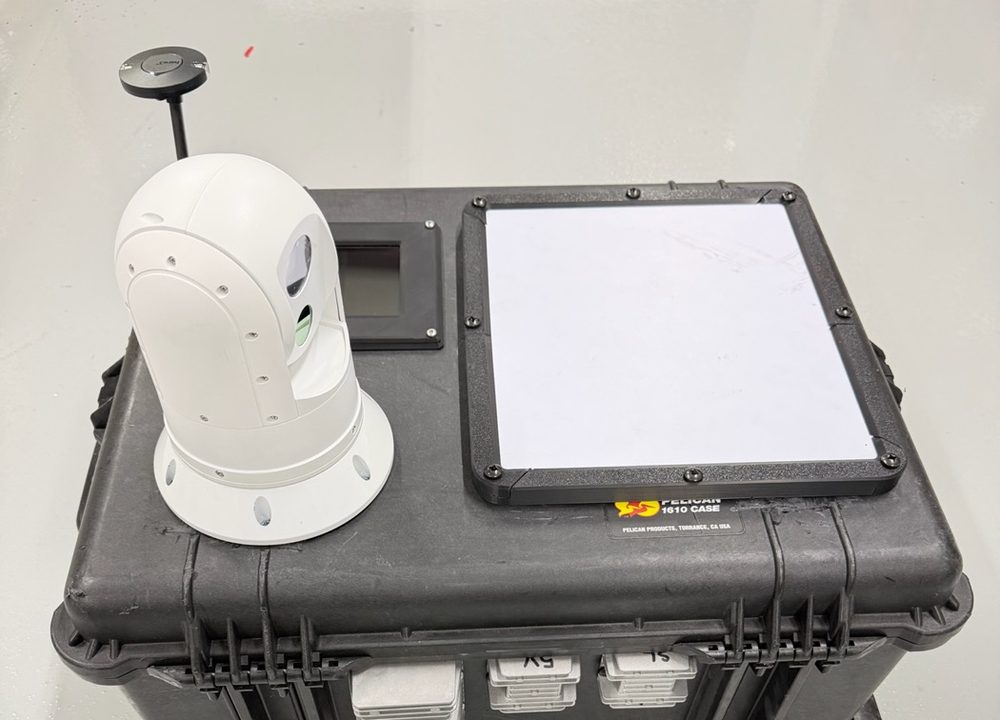
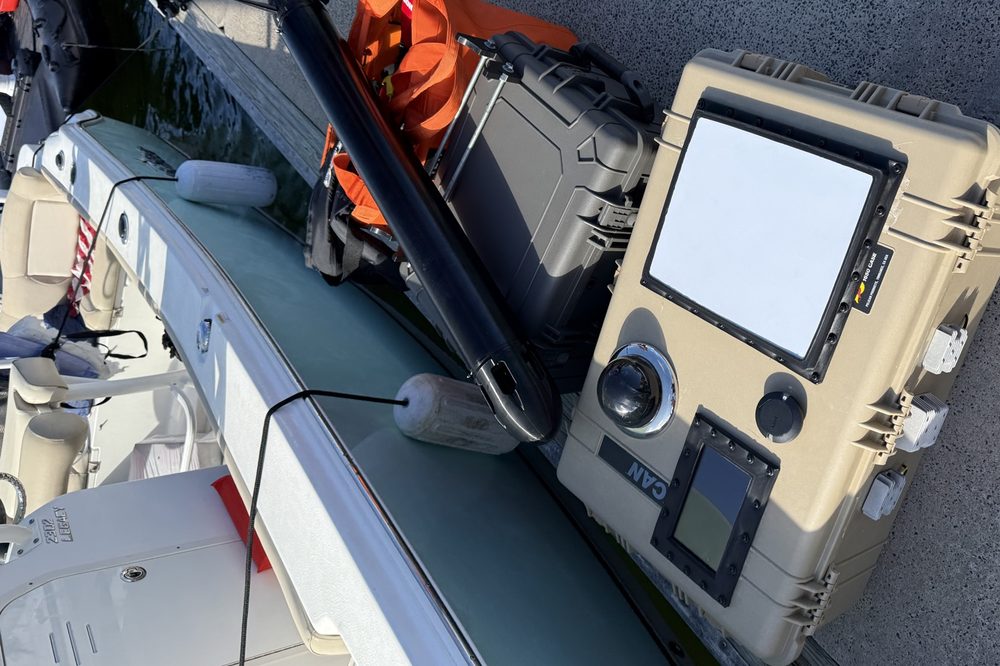
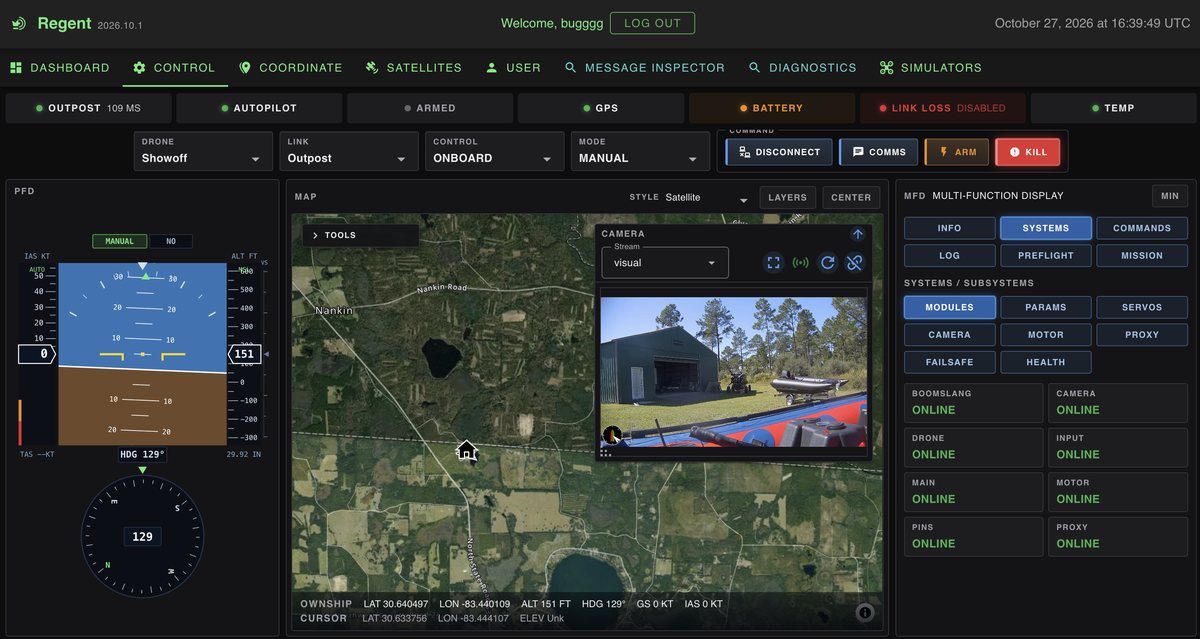
A FastAPI mission-control server that rides on a Raspberry Pi strapped to the autopilot — the brain inside GreyCliff's Drone-in-a-Box kit. A supervised module system owns the MAVLink connection, broadcasts telemetry at 10 Hz over WebSocket, handles mission upload/download with progress tracking, streams live video over RTSP, drives an e-ink status dashboard, and reads joystick input with deadzones and exponential curves. It also publishes typed client packages that the ground server consumes by version.
Overview
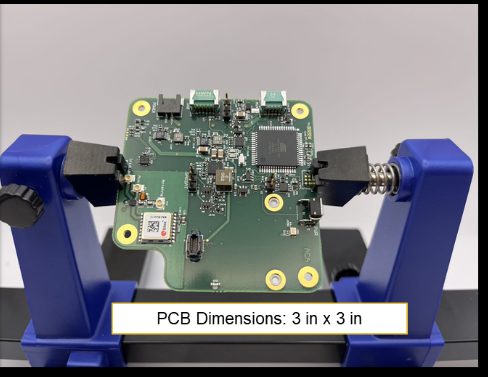
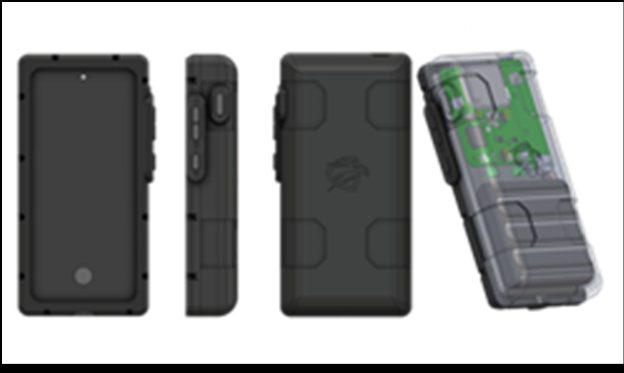
The software half of SIDEARM, GreyCliff's operational Iridium SATCOM gateway: an HTTP API that bridges a satellite modem to a ground control station for when the vehicle is far past the last cell tower. Encrypted bi-directional messaging, a binary codec that packs waypoints, telemetry and 20+ command types into tiny satellite frames, a beacon mode that schedules transmissions around satellite passes using ephemeris data, and an async transaction queue so nothing gets lost over a flaky link.
Overview
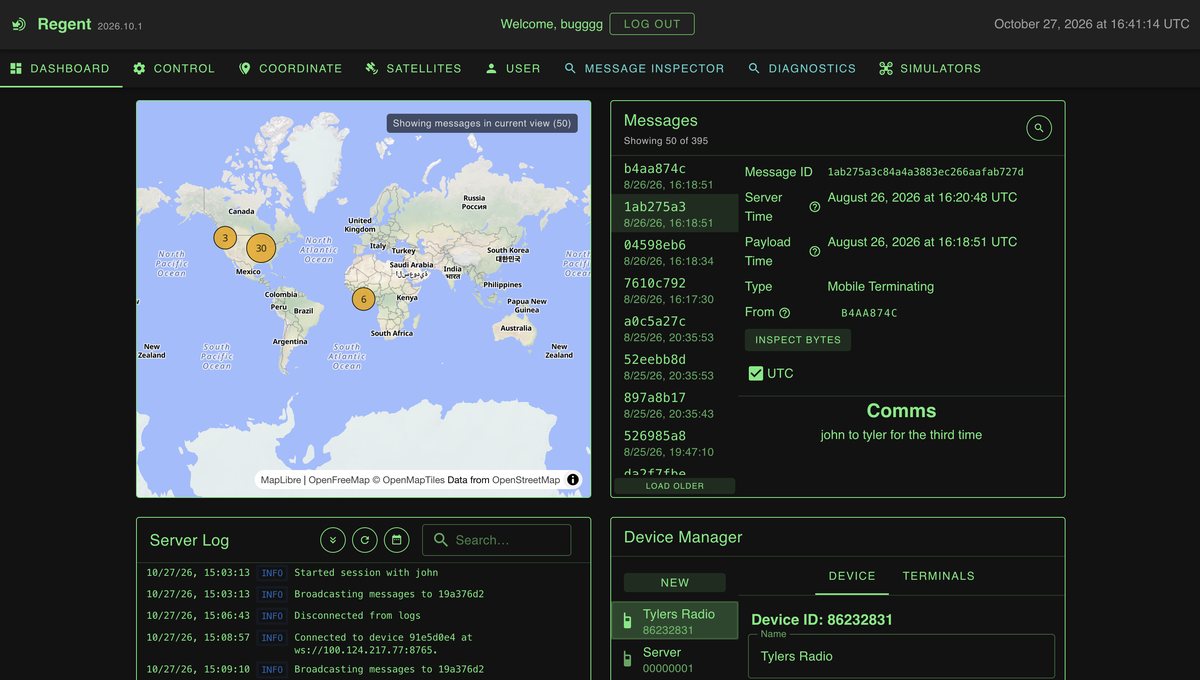
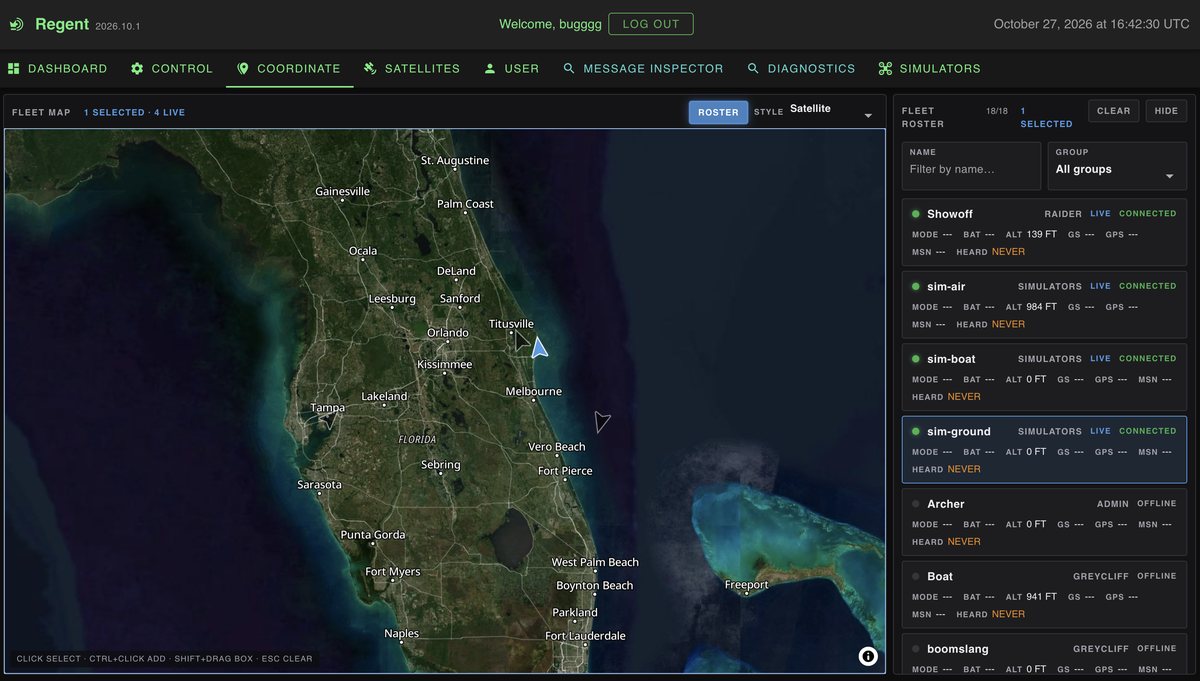
The Battlespace Server — the ground end of the satellite link, where PiShieldLight and ShieldFRNT are the field ends. A Vue 3 + MapLibre operator console talks REST and WebSocket to a FastAPI backend with a separate worker process, visualizing device positions and routing encrypted message traffic over Iridium SBD for platforms like BOATIE. Postgres sits behind Alembic migrations, satellite pass windows come from ephemeris math, and the frontend's TypeScript types are generated straight from the backend's OpenAPI schema. It consumes OUTPOST's published client packages by version, so the two systems evolve in lockstep.
Overview
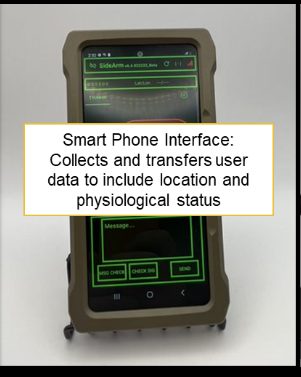
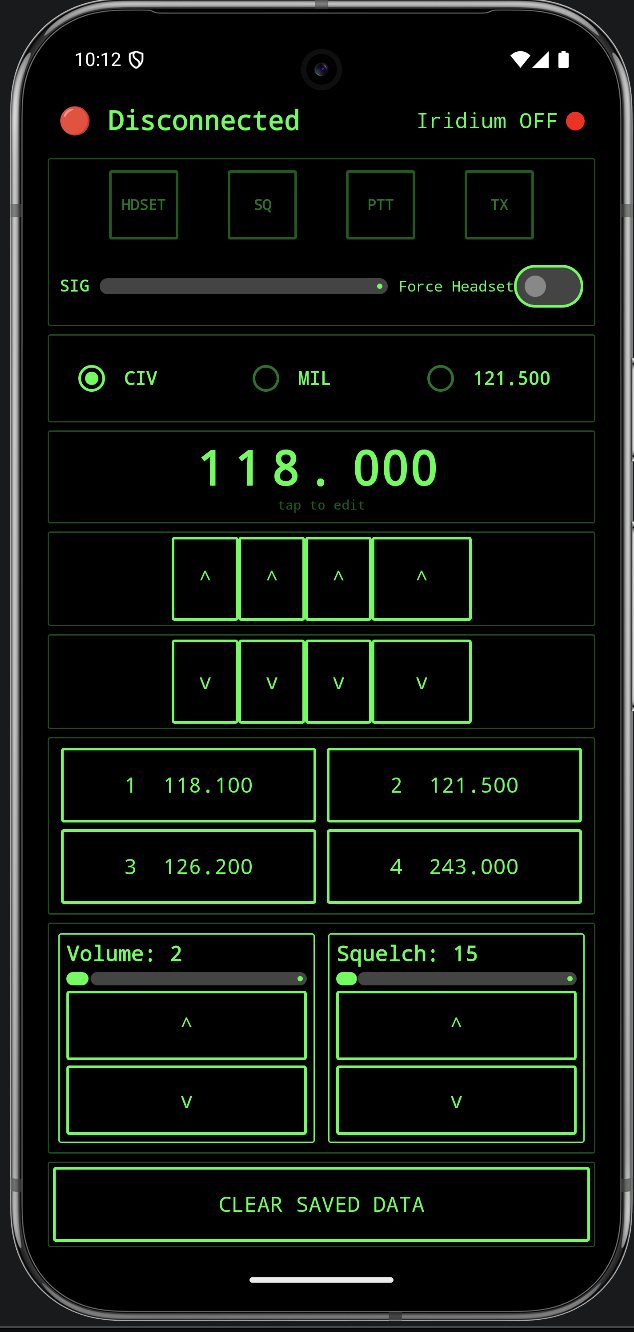
The operator's end of the SIDEARM gateway: an Android controller for Iridium satellite modems in the field. Compose a message, it gets encrypted, queued, and transmitted over a USB serial link to the modem — with background services draining the outbound queue and babysitting the hardware connection. GPS tracking, inbox, device configuration and session management across eight fragments, all backed by a Room database in a clean MVVM architecture.
Overview
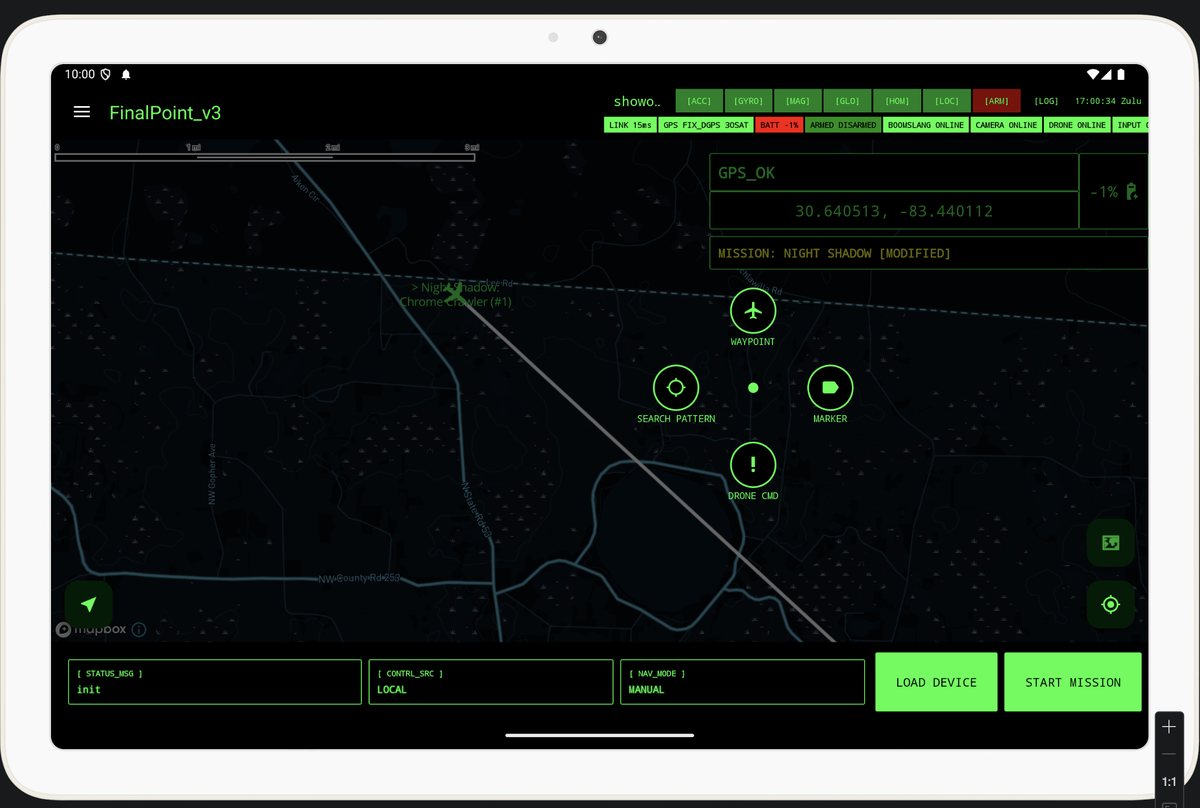
A real-time air and sea traffic monitor for Android. Three concurrent WebSocket feeds — ADS-B aircraft, AIS vessels, and server status — run through a priority queue onto a live Mapbox display, with filtering, detail panels, and route history persisted in Room. A companion planning mode — FinalPoint — handles waypoints, search patterns, and drop-point selection for airdrop missions.
Overview
A real-time transcription daemon for the Raspberry Pi 5: one process records audio in ten-second chunks, another runs them through OpenAI Whisper on-device — no cloud, no connectivity required. Model sizes scale from tiny.en up to medium.en depending on how much latency the mission can tolerate.
Overview
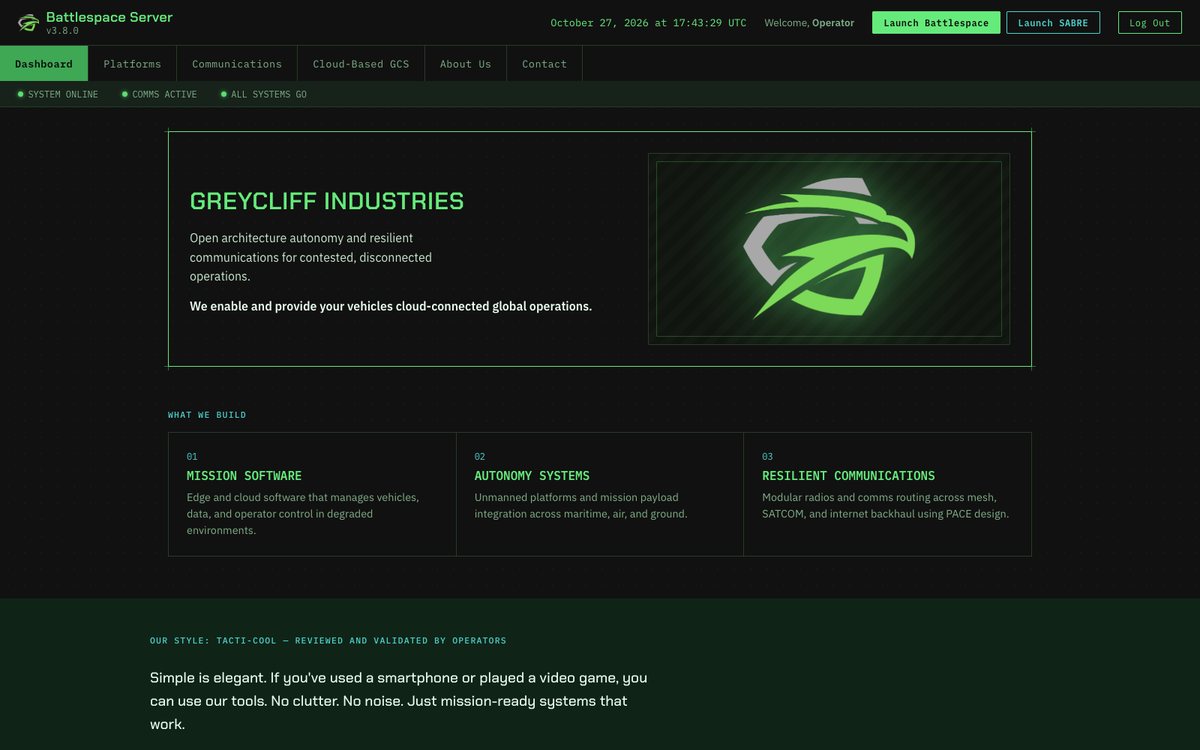
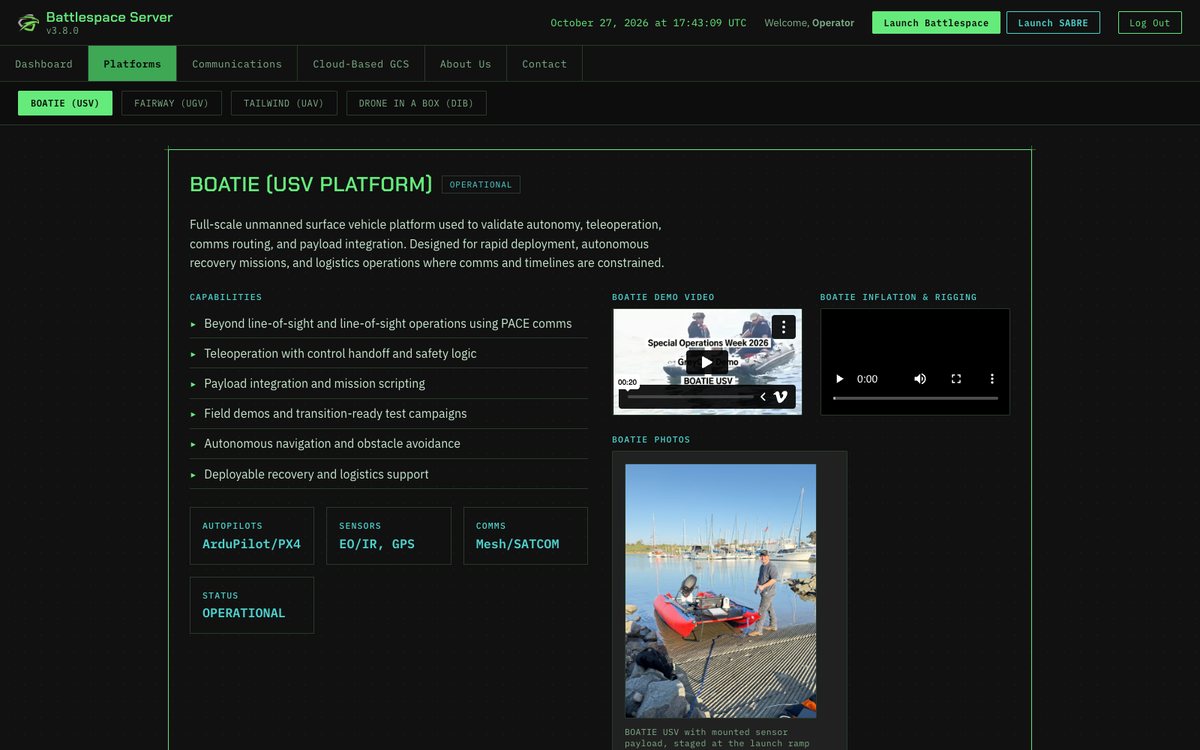
The public face of GreyCliff Industries, live at gcliffindustries.com — a Vue 3 single-page app styled as the company's own Battlespace Server console. Product pages are fully data-driven: every platform and radio is a plain object in a data file, rendered through one shared ProductCard component, so adding a product never touches layout code. Design tokens drive the whole theme, routes are lazy-loaded, and the site ships as a containerized nginx build deployed to Google Cloud Run through GitLab CI.
// Field-tested capabilities
SATELLITE COMMS
Iridium SBD links end to end: binary codecs, encrypted store-and-forward queues, and beacons scheduled around satellite passes.
VEHICLE AUTONOMY
MAVLink and MAVSDK mission control for drones and boats — upload, track, pause, return, kill.
REAL-TIME TELEMETRY
10 Hz WebSocket pipelines from autopilot to browser and Android, with priority queues when the data firehose gets loud.
EDGE HARDWARE
Raspberry Pi field servers, USB serial modems, e-ink dashboards, kiosk touchscreens — deployed with Docker and systemd.
// Open a channel
MAKE CONTACT
Go ahead — the link is up and the queue is empty
tbugaj444@gmail.com
Transmit